Monday, December 24, 2018

Heat treatment processes

 
Summarizes and definitions of the some common heat treatment processes like annealed, normalized, quench hardened and tempered are given below.

Annealed: 
Annealed is the condition of a metal that has been heated above a specific temperature, depending upon its composition and then cooled down in the furnace itself or by burying it in ashes or lime. This annealing process makes the metal very soft and ductile. Annealing usually precedes flow-forming operations such as sheet metal pressing and wire tube drawing.

Normalized: 
Normalizing is the condition of a metal that has been heated above a specific temperature, depending upon its composition and then cooled down in free air. Although the cooling is slow, it is not as for annealing so the metal is less soft and ductile. This condition is not suitable for flow forming but more suitable machining. Normalizing is often used to stress relieve castings and forgings after rough machining.

Quench hardened: 
Quench hardened is the condition of a metal that has been heated above a specific temperature, depending upon its composition and then cooled down very rapidly by immersing it in cold water or cold oil. Rapid cooling is called quenching and the water or oil is called the quenching bath. This rapid cooling from elevated temperatures makes the metal very hard. Only medium-carbon steels and high-carbon steels can be hardened in this way.

Tempered: 
Quench-hardened steels are brittle as well as hard. To make them suitable for cutting tools they have to be reheated to a specified temperature below 200 to 300°C and again quenched. This makes them slightly less hard but very much tougher. Metals in this condition are said to be tempered.

Governor Types – Centrifugal Governor and Inertia Governor

Governor is a device used to maintain the speed of an engine within specified limits when the engine works in varying of different loads.
Based on the source of controlling force, the governors can be classified into two types. Governor types are centrifugal governors and inertia governors.
Centrifugal Governors :
In centrifugal governors, multiple masses know as governor balls, are responsible to revolve about the axis of a shaft, which is driven through suitable gearing from the engine crankshaft. Each ball is acted upon by a force which acts in the radially inward direction and is provided by dead weight, a spring or a combination of two. This force is commonly called as the controlling force and it will increase as the distance of the ball from the axis of rotation increases. The inward or outward movement of the ball is transmitted by the governor mechanism to the valve which controls the amount of energy supplied to the engine.
                           
Centrifugal governor
Inertia Governor :
In inertia governors, the balls are arranged in manner that the inertia forces caused by angular acceleration or retardation of the governor shaft tend to change their position. The obvious advantage of inertia governor lies in its rapid response to the effect of a change of load. This advantage is small, however by the practical difficulty of arranging for the complete balance of the revolving parts of the governor. For this reason Centrifugal governors are preferred over the inertia governors.

Types of loads

                                            
Different types of loads  in engineering mechanics are compression, tension, torsion and bending.Compression, tension, torsion and bending loads.
Compression loading is an effect in which the component reduces it size. During compression load there is reduction in volume and increase in density of a component.
Tension is the act of stretching rod, bar, spring, wire, cable etc. that is being pulled from the either ends.
Torsion is the act of twisting of an rod, wire, spring etc. about an axis due to applied couple (torque).
Bending is act of changing component from straight form into a curved or angular form.

Types of mechanical forces

A force exerted on a body can cause a change in either the shape or the motion of the body. The unit of force in SI system is the newton (N) and CGS system is dyne. No solid body is perfectly rigid and when forces are applied to it, changes in dimensions occur. Such changes are not always perceptible to the human eye since they are negligible. For example, the span of a bridge will sag under the weight of a vehicle and a spanner will bend slightly when tightening a nut. It is important for civil engineers and designers to appreciate the effects of forces on materials, together with their mechanical properties of materials.
There are three main types of mechanical forces that can act on a body. They are:
                                                                
1.      Tensile force
2.      Compressive force and
3.      Shear force

Tensile force that tends to stretch a material, as shown in the figure 1 below.
Tensile force
Figure 1: Tensile force
For example,
1.      Rubber bands, when stretched, are in tension.
2.      The rope or cable of a crane carrying a load is in tension.
3.      When a nut is tightened, a bolt is under tension.
A tensile force will increases the length of the material on which it acts.


What is Compression Force?


Compression force (or compressive force) occurs when a physical force presses inward on an object, causing it to become compacted. In this process, the relative positions of atoms and molecules of the object change. This change can be temporary or permanent depending on the type of material receiving the compressive force. There can also be different results depending on the direction or position on the object that the compressive force is applied.

What is shear force?

Shear force is a force that acts on a plane passing through the body. Shear forcesare forces that are unaligned and separates structure in to two different parts in inverse direction.Shear force acts in a perpendicular direction to the large part (length) of the structure. 

Super chargers

Super charger acts as an air compressor. It is used to increase the density and pressure of the air that is supplied to the internal combustion engine. In the engine, during the intake of the cycle it takes more oxygen and burn more fuel to accomplish the work. This is due the power increase.
By using the belts, gears, shafts, chains all of these are connected to the engines crank shaft to produce super charge.
We can see two types of the super chargers. To that matter after super charging, the air enters into the engine. After compression the pressure in the air is compressed and it super charges the system by 1.5 to 2 times to increase the entry of the pressure.
In one type of the super charger the engine shaft is mechanically linked to the shaft. The shaft energy must turn into useful work input for the super charger.
In another type of the super charger the compressor is attached to the turbine. Exhaust gas must be allowed to enter into the turbine. The turbine drives the super charger; this type of super charger is known as the turbo 
Super chargers
Super charger drive types:
They are divided into mechanical, exhaust gas turbine and other types:
Mechanical drives are divided into four types they are belt drive, chain drive, direct drive and gear drive.
Exhaust gas turbines are divided into two types they are radial turbine and axial turbine.
And the other type of the drives is electrical motor and auxiliary power unit.
Advantages of supercharger:
  • The work output and the overall efficiency of the engine must be increased by 50% of the supercharger.
  • At the higher heights, the low density air is converted into the normal density air.
  • In the supercharge engine the specific fuel consumption is saved
  • In the volumetric efficiency of the super charger engine will be higher
  • To run the super charger, exhaust gas must be re-circulated in the engine. In this case the work input will be increases.
  • In the super charged engine the scavenging is improved.

Disadvantages of supercharger:
  • On the engine, different moving parts are observed like the thermal stress, mainly on the bearing of the engine shafts.
  • So it results in the wear and tear in the moving parts
  • We need to replace the parts frequently in the engine
  • During the time of compression stroked by the piston there is a leakage of the air in the super charge engine
  • Due to the super charging, the temperature of the air entering the engine cylinder will be higher.
  • The detonation tendency of the engine increases.
  • In the petrol engine, the detonation reduces so inter coolers are used to increases the size of the engine.
  • click on this link below for detailed explaination.

Monday, June 11, 2018

laser ignition system

Abstract

Economic as well as environmental constraints demand a further reduction in the fuelconsumption and the exhaust emissions of motor vehicles. At the moment, directInjected fuel engines show the highest potential in reducing fuel consumption and exhaust emissions. Unfortunately, conventional spark plug ignition shows a major disadvantage with modern spray-guided combustion processes since the ignition location cannot be chosen optimally.
It is important that the spark plug electrodes are not hit by the injected fuel because otherwise severe damage will occur.Additionally, the spark plug electrodes can influence the gas flow inside the combustion chamber. It is well know that short and intensive laser pulses are able to produce an ”optical breakdown” in air. Necessary intensities are in the range between 1010- 1011W/cm2.1, 2 at such intensities, gas molecules are dissociated and ionized Within the vicinity of the focal spot of a laser beam and a hot plasma is generated. ThisPlasma is heated by the incoming laser beam and a strong shock wave occurs. The expanding hot plasma can be used for the ignition of fuel-gas mixtures.

Drawbacks Of Conventional Spark Ignition

Location of spark plug is not flexible as it require shielding of plug from immense heat and fuel spray.
It is not possible to ignite inside the fuel spray.
It require frequent maintenance to remove carbon deposits..
Leaner mixtures cannot be burned.
Degradation of electrodes at high pressure and temperature.
Flame propagation is slow.
Multi point fuel ignition is not feasible.
Higher turbulence levels are required.

What Is Laser?

Lasers provide intense and unidirectional beam of light. Laser light is monochromatic (onespecific wavelength). Wavelength of light is determined by amount of energy releasedwhen electron drops to lower orbit. Light is coherent; all the photons have same wavefronts that launch to unison. Laser light has tight beam and is strong and concentrated.
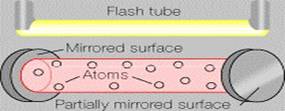
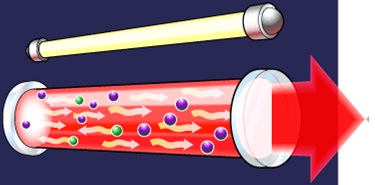
Tomake these three properties occur takes something called “Stimulated Emission”, inwhich photon emission is organized. Main parts of laser are power supply, lasing medium and a pair of precisely aligned mirrors. One has totally reflective surface and other is partially reflective (96 %). The most important part of laser apparatus is laser crystal. Most commonly used laser crystalis manmade ruby consisting of aluminum oxide and 0.05% chromium. Crystal rods are round and end surfaces are made reflective.
A laser rod for 3 J is 6 mm in diameter and70 mm in length approximately. Laser rod is excited by xenon filled lamp, whichsurrounds it. Both are enclosed in highly reflective cylinder, which directs light fromflash lamp in to the rod. Chromium atoms are excited to higher energy levels. The excitedions meet photons when they return to normal state. Thus very high energy is obtained inshort pulses. Ruby rod becomes less efficient at higher temperatures, so it is continuouslycooled with water, air or liquid nitrogen. The Ruby rod is the lasing medium and flashtube pumps it.
Laser Ignition System
Ruby Laser
Ruby Laser

Laser Induced Spark Ignition

The process begins with multi-photon ionization of few gas molecules which releaseselectrons that readily absorb more photons via the inverse bremsstrahlung process toincrease their kinetic energy. Electrons liberated by this means collide with othermolecules and ionize them, leading to an electron avalanche, and breakdown of the gas.Multiphoton absorption processes are usually essential for the initial stage of breakdownbecause the available photon energy at visible and near IR wavelengths is much smaller than the ionization energy.
For very short pulse duration (few picoseconds) themultiphoton processes alone must provide breakdown, since there is insufficient time forelectron-molecule collision to occur. Thus this avalanche of electrons and resultant ionscollide with each other producing immense heat hence creating plasma which issufficiently strong to ignite the fuel. The wavelength of laser depend upon the absorptionproperties of the laser and the minimum energy required depends upon the number ofphotons required for producing the electron avalanche.
Laser Induced Spark Ignition
The minimum ignition energy required for laser ignition is more than that for electric spark ignition because of following reasons: An initial comparison is useful for establishing the model requirements, and for identifying causes of the higher laser MIE. First, the volume of a typical electrical ignition spark is 10^-3 cm3. The focal volume for a typical laser spark is 10^-5 cm3. Since atmospheric air contains _1000 charged particles/cm3, the probability of finding a charged particle in the discharge volume is very low for a laser spark. Second, an electrical discharge is part of an external circuit that controls the power input, which may last milliseconds, although high power input to ignition sparks isusually designed to last <100 ns.
Breakdown and heating of laser sparks depend only onthe gas, optical, and laser parameters, while the energy balance of spark dischargesdepends on the circuit, gas, and electrode characteristics. The efficiency of energytransfer to near-threshold laser sparks is substantially lower than to electrical sparks, somore power is required to heat laser sparks. Another reason is that, energy in the form of photons is wasted before the beam reach the focal point. Hence heating and ionizing the charge present in the path of laserbeam. This can also be seen from the propagation of flame which propagates longitudinally along the laser beam. Hence this loss of photons is another reason forhigher minimum energy required for laser ignition than that for electric spark.

Advantages

 Location of spark plug is flexible as it does not require shielding from immense heat and fuel spray and focal point can be made any where in thecombustion chamber from any point It is possible to ignite inside the fuel spray asthere is no physical component at ignition location.
 It does not require maintenance to remove carbon deposits because of itsself cleaning property.
 Leaner mixtures can be burned as fuel ignition inside combustion chamberis also possible here certainty of fuel presence is very high.
 High pressure and temperature does not affect the performance allowing the use of high compression ratios.
 Flame propagation is fast as multipoint fuel ignition is also possible.
 Higher turbulence levels are not required due to above said advantages

electromagnetic clutch system

Abstract

A clutch is a mechanism for transmitting rotation, which can be engaged and disengaged. Clutches are useful in devices that have two rotating shafts. In these devices, one shaft is typically driven by motor or pulley, and other shaft drives another device. The clutch connects the two shafts so that they can either be locked together and spin at the same speed (engaged), or be decoupled and spin at different speeds (disengaged).
The clutch disc (centre) spins with the flywheel (left). To disengage, the lever is pulled (black arrow), causing a white pressure plate (right) to disengage the green clutch disc from turning the drive shaft, which turns within the thrust-bearing ring of the lever. Never will all 3 rings connect, with any gaps.

Electromagnetic Clutch

Electromagnetic clutches operate electrically, but transmit torque mechanically. This is why they used to be referred to as electro-mechanical clutches.

CONSTRUCTION

A horseshoe magnet has a north and south pole. If a piece of carbon steel contacts both poles, a magnetic circuit is created. In an electromagnetic clutch, the north and south pole is created by a coil shell and a wound coil. In a clutch, when power is applied, a magnetic field is created in the coil. This field (flux) overcomes an air gap between the clutch rotor and the armature. This magnetic attraction, pulls the armature in contact with the rotor face. The frictional contact, which is being controlled by the strength of the magnetic field, is what causes the rotational motion to start.
The torque comes from the magnetic attraction, of the coil and the friction between the steel of the armature and the steel of the clutch rotor. For many industrial clutches, friction material is used between the poles. The material is mainly used to help decrease the wear rate, but different types of material can also be used to change the coefficient of friction (torque for special applications). For example, if the clutch is required to have an extended time to speed or slip time, a low coefficient friction material can be used and if a clutch is required to have a slightly higher torque (mostly for low rpm applications), a high coefficient friction material can be used.
In a clutch, the electromagnetic lines of flux have to pass into the rotor, and in turn, attract and pull the armature in contact with it to complete clutch engagement. Most industrial clutches use what is called a single flux, two pole design. Mobile clutches of other specialty electromagnetic clutches can use a double or triple flux rotor. The double or trip flux refers to the number of north/south flux paths, in the rotor and armature.
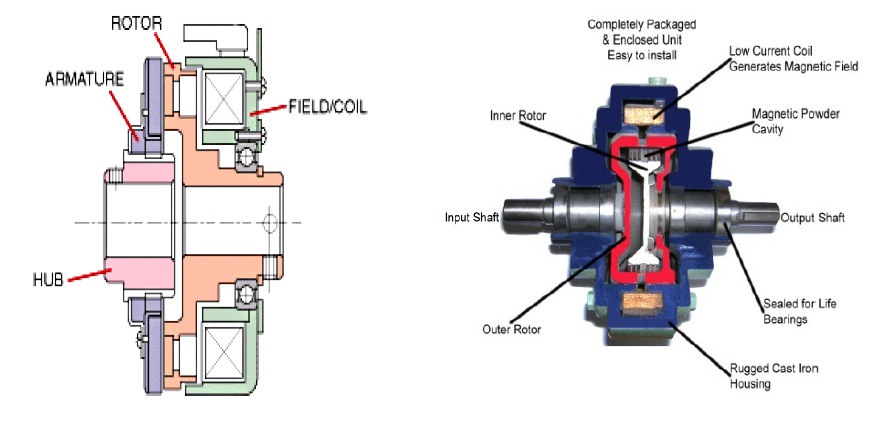
Electromagnetic Clutch
This means that, if the armature is designed properly and has similar banana slots, what occurs is a leaping of the flux path, which goes north south, north south. By having more points of contact, the torque can be greatly increased. In theory, if there were 2 sets of poles at the same diameter, the torque would double in a clutch. Obviously, that is not possible to do, so the points of contact have to be at a smaller inner diameter. Also, there are magnetic flux losses because of the bridges between the banana slots. But by using a double flux design, a 30%-50% increase in torque, can be achieved, and by using a triple flux design, a 40%-90% in torque can be achieved. This is important in applications where size and weight are critical, such as automotive requirements.
The coil shell is made with carbon steel that has a combination of good strength and good magnetic properties. Copper (sometimes aluminium) magnet wire, is used to create the coil, which is held in shell either by a bobbin or by some type of epoxy/adhesive.
To help increase life in applications, friction material is used between the poles on the face of the rotor. This friction material is flush with the steel on the rotor, since if the friction material was not flush, good magnetic traction could not occur between the faces. Some people look at electromagnetic clutches and mistakenly assume that, since the friction material is flush with the steel that the clutch has already worn down but this is not the case. Clutches used in most mobile applications, (automotive, agriculture, construction equipment) do not use friction material. Their cycle requirements tend to be lower than industrial clutches, and their cost is more sensitive. Also, many mobile clutches are exposed to outside elements, so by not having friction material, it eliminates the possibility of swelling (reduced torque), that can happen when friction material absorbs moisture.

How Does It Works

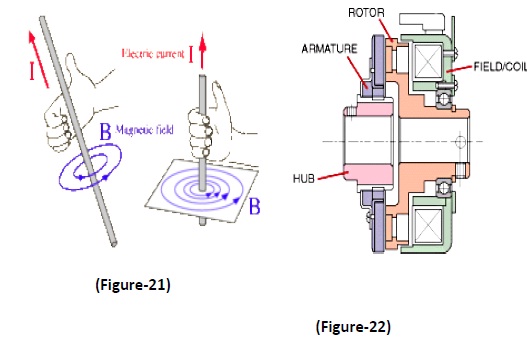
The clutch has four main parts: field, rotor, armature, and hub (output) . When voltage is applied the stationary magnetic field generates the lines of flux that pass into the rotor. (The rotor is normally connected to the part that is always moving in the machine.) The flux (magnetic attraction) pulls the armature in contact with the rotor (the armature is connected to the component that requires the acceleration), as the armature and the output start to accelerate. Slipping between the rotor face and the armature face continues until the input and output speed is the same (100% lockup). The actual time for this is quite short, between 1/200th of a second and 1 second.
Disengagement is very simple. Once the field starts to degrade, flux falls rapidly and the armature separates. One or more springs hold the armature away from the rotor at a predetermined air gap.

Basic operation of electromagnetic clutch

• The clutch has four main parts: field, rotor, armature, and hub (output) (Figure-22). When voltage is applied the stationary magnetic field generates the lines of flux that pass into the rotor. (The rotor is normally connected to the part that is always moving in the machine.) The flux (magnetic attraction) pulls the armature in contact with the rotor (the armature is connected to the component that requires the acceleration), as the armature and the output start to accelerate. Slipping between the rotor face and the armature face continues until the input and output speed is the same (100% lockup). The actual time for this is quite short, between 1/200th of a second and 1 second.
Electromagnetic Clutch
• Disengagement is very simple. Once the field starts to degrade, flux falls rapidly and the armature separates. One or more springs hold the armature away from the rotor at a predetermined air gap.
• Voltage/current - and the magnetic field
• If a piece of copper wire was wound, around the nail and then connected to a battery, it would create an electro magnet. The magnetic field that is generated in the wire, from the current, is known as the “right hand thumb rule”. (FIGURE-21) The strength of the magnetic field can be changed by changing both wire size and the amount of wire (turns). EM clutches are similar; they use a copper wire coil (sometimes aluminum) to create a magnetic field.
• The fields of EM clutch can be made to operate at almost any DC voltage, and the torque produced by the clutch or brake will be the same, as long as the correct operating voltage and current is used with the correct clutch. If a 90 V clutch, a 48 V clutch and a 24 V clutch, all being powered with their respective voltages and current, all would produce the same amount of torque. However, if a 90 V clutch had 48 V applied to it, this would get about half of the correct torque output of that clutch. This is because voltage/current is almost linear to torque in DC electromagnetic clutches.
• A constant power supply is ideal if accurate or maximum torque is required from a clutch. If a non regulated power supply is used, the magnetic flux will degrade, as the resistance of the coil goes up. Basically, the hotter the coil gets the lower the torque will be, by about an average of 8% for every 20°C. If the temperature is fairly constant, but there may not be enough service factor in your design for minor temperature fluctuation. Over-sizing, the clutch would compensate for minor flux. This will allow the use a rectified power supply which is far less expensive than a constant current supply.
• Based on V = I × R, as resistance increases available current falls. An increase in resistance, often results from rising temperature as the coil heats up, according to: Rf = Ri × [1 + αCu × (Tf - Ti)] Where Rf = final resistance, Ri = initial resistance, αCu = copper wire’s temperature coefficient of resistance, 0.0039 °C-1, Tf = final temperature, and Ti = initial temperature.

Engagement time

There are actually two engagement times to consider in an electromagnetic clutch. The first one is the time that it takes for a coil to develop a magnetic field, strong enough to pull in an armature. Within this, there are two factors to consider. The first one is the amount of ampere turns in a coil, which will determine the strength of a magnetic field. The second one is air gap, which is the space between the armature and the rotor. Magnetic lines of flux diminish quickly in the air.. Air gap is an important consideration especially with a fixed armature design because as the unit wears over many cycles of engagement the armature and the rotor will create a larger air gap which will change the engagement time of the clutch. In high cycle applications, where registration is important, even the difference of 10 to 15 milliseconds can make a difference, in registration of a machine. Even in a normal cycle application, this is important because a new machine that has accurate timing can eventually see a “drift” in its accuracy as the machine gets older.
The second factor in figuring out response time of a clutch is actually much more important than the magnet wire or the air gap. It involves calculating the amount of inertia that the clutch needs to accelerate. This is referred to as “time to speed”. In reality, this is what the end-user is most concerned with. Once it is known how much inertia is present for the clutch to start then the torque can be calculated and the appropriate size of clutch can be chosen.
Most CAD systems can automatically calculate component inertia, but the key to sizing a clutch is calculating how much inertial is reflected back to the clutch or brake. To do this, engineers use the formula: T = (wk2 × ΔN) / (308 × t) Where T = required torque in lb-ft, WK2 = total inertia in lb-ft2, ΔN = change in the rotational speed in rpm, and t = time during which the acceleration or deceleration must take place.
There are also online sites that can help confirm how much torque is required to accelerate a given amount of inertia over a specific time.

CONCLUSION

Having designed and constructed the circuit it was felt that it met all of the given specifications although there were still a number of improvements that could have been made. These improvements have been covered briefly in the discussion section and given more time they could have been implemented in the circuit. As already mentioned the only specifications not met were that on start-up the machine should rotate for 3 seconds in one direction before braking and reversing. Using the clutch method mentioned in the discussions could solve this but the design brief given did not extend to cover the drum so has not been included in the final design.
During the course of the project a number of other points became evident which greatly ease the process of designing an electronic circuit. Simulation using a computer package such as Pspice saves a considerable amount of time by allowing the circuit to be easily laid out and tested. Any changes required can be made easily without disturbing the rest of the circuit. Another advantage of Pspice is the ability to produce graphs of the outputs from the circuit, which can then be scaled, formatted and printed as required. To do this for the actual circuit requires very specialised and expensive equipment.
In conclusion, the group felt that all objectives had been met and that the final circuit was successful in fulfilling its role. A number of important lessons were learned about the problems involved in designing a circuit to meet a real-world need and ways of overcoming these problems were found.